RSSI is signal strength, not distance
The cage never left Bay 4. On the map it just jumped three bays left. A forklift rolled past, the tag sat behind a steel rack face, and the receiver heard a quieter packet. The location engine treated quieter as farther. The hunt started for an asset that had not moved.
What RSSI actually measures
RSSI (Received Signal Strength Indicator) is how loud a radio packet sounds to the receiver, usually reported in dBm. More negative means weaker. It is a power sample, not a tape measure. Indoor RTLS stacks that run on BLE or Wi-Fi often turn those samples into a guessed distance or a rough coordinate. The guess starts from a simple idea: weaker signal, farther tag.
That idea needs an open path and a stable fade rate. On a plant floor neither holds for long. The same loudness can mean 1 m (3 ft) in an open aisle or much less when metal, bodies, and orientation sit in the way. Industrial indoor positioning research keeps repeating the same limit: RSSI alone is a weak meter stick once shelves, movers, and reflections enter the path.
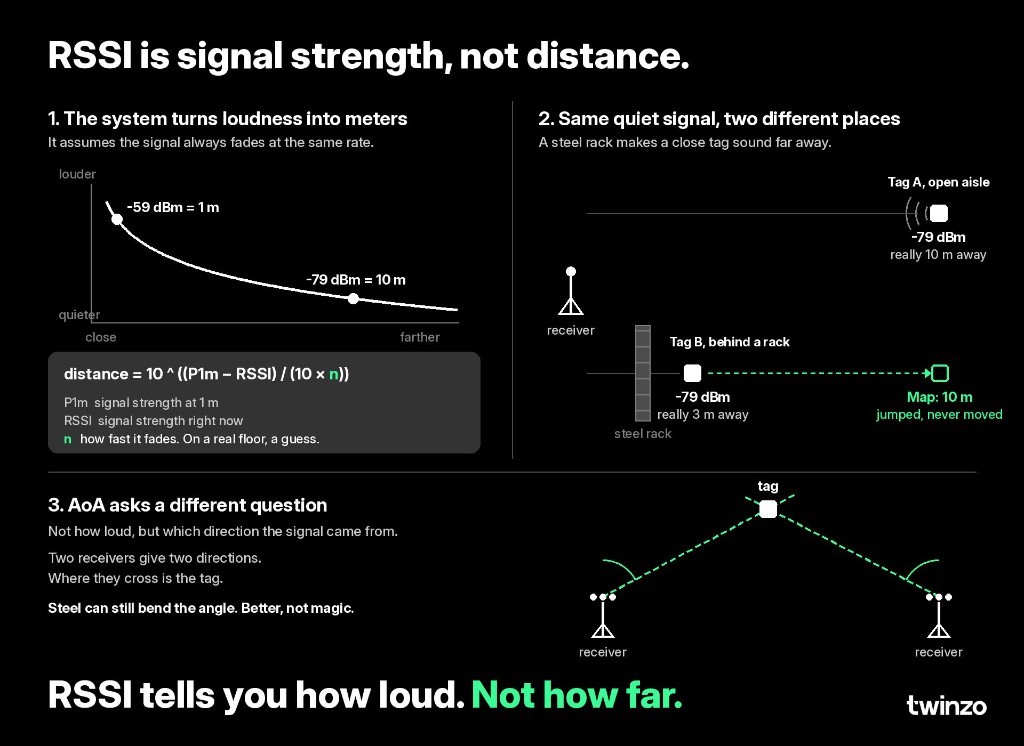
How the system turns loudness into meters
Location engines often map RSSI through a path-loss model. In open space a louder reading near about -59 dBm might map near 1 m (3 ft), and a quieter reading near about -79 dBm might map near 10 m (33 ft). The formula still needs a fade exponent, usually written as n. On a real floor that exponent is a guess that changes with racking, WIP height, and who is standing in the aisle.
So the map is not reading distance. It is reading loudness and converting it with assumptions. When the assumptions break, the location jumps even though the tagged asset stayed put.
Same quiet signal, two different places
Picture one receiver. Tag A sits 10 m (33 ft) away in an open aisle and reports about -79 dBm. Tag B sits only 3 m (10 ft) away, but behind a steel rack, and also reports about -79 dBm. The engine that trusts loudness as distance treats both as the far mark. Tag B never moved. On the map it jumped to the 10 m (33 ft) ring.
Steel racks are the obvious blocker. A forklift passing through the line of sight, a person walking past the tag, a flipped antenna face, and multipath reflections do the same job: they change loudness without a true move. That is why RSSI-based BLE in metal halls often lands in a rough band around 3–10 m (10–33 ft) when teams are honest about the environment, as covered in BLE for RTLS.
Fine for zone presence, weak for bay identity
RSSI is often enough when the decision is coarse zone presence: is the truck in this wing, past this gate, or still in the dock hall? Many search and fleet jobs only need that scale. It is a poor answer when the decision is which bay holds the cage, or whether the load sits on the exact floor mark. Medium-precision aisle work in the 1–3 m (3–10 ft) band usually needs a cleaner method than raw loudness, or at least denser anchors and heavier filtering. Exact floor position in the sub-meter (~3 ft) band is a different job again.
Match the radio method to the decision before you buy hardware. That order sits under start with the decision, not the technology. The wider RTLS definition is in what is RTLS.
AoA asks a different question
Other algorithms stop treating loudness as the main ruler. Angle of Arrival (AoA) asks which direction the packet came from. A multi-antenna receiver reads phase across its array. Two receivers give two directions. Where those directions cross is the estimated tag location. The measurement is geometry, not a single dBm number.
Steel can still bend the angle. Reflections create ghost directions. AoA is better for many bay-scale BLE jobs when arrays and line of sight hold. It is not magic. Inside the BLE family it sits beside classic and inverted RSSI builds, not as a different radio religion. How those three BLE builds compare is in BLE for RTLS. How precision bands sit across technologies is in compare RTLS technologies.
How teams use the distinction on site
1. Name the floor question in meters - Zone presence, aisle or bay search, or exact floor position. Do not buy a brochure accuracy number first.
2. Treat unexplained map jumps as radio weather - Ask what blocked or reflected the path before you blame the driver or the twin.
3. Pick the method that answers the question - RSSI proximity for coarse presence. Direction finding or other ranging methods when bay identity matters. Then land the stream on one hall view for internal logistics and production monitoring.
RSSI tells you how loud. Not how far. Get in touch if you want to test which location method matches the decisions on your own hall.